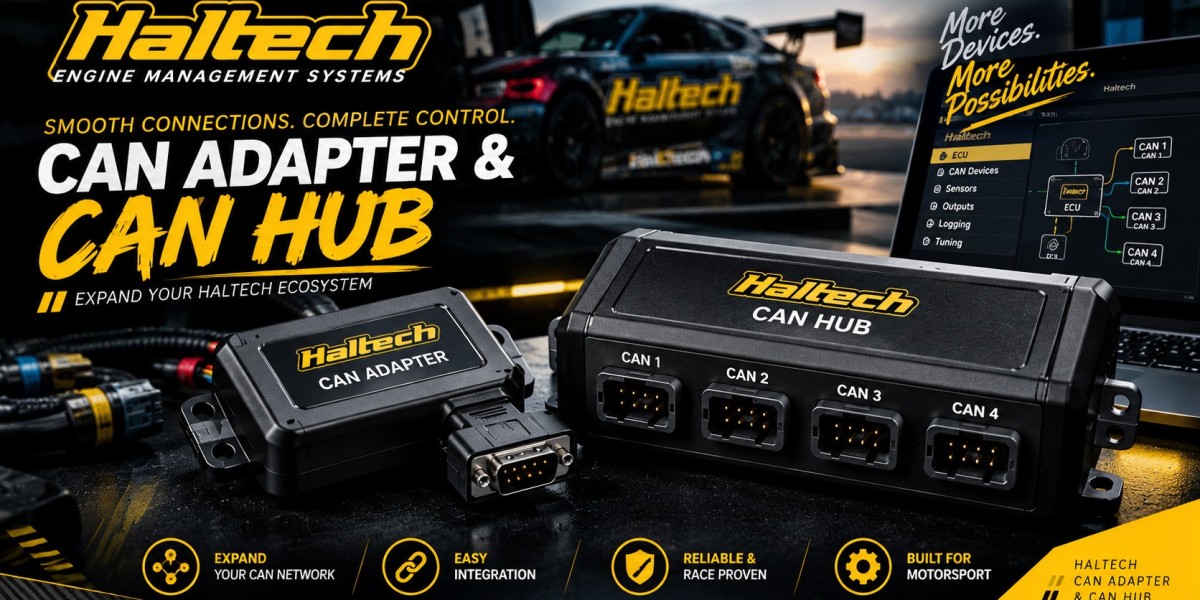
Think about everything your engine management system knows: engine speed, throttle position, manifold pressure, coolant and intake temperatures, lambda, ignition timing, boost target. Without a way to share that information, it stays trapped inside the ECU. Haltech CAN communication releases it, letting the ECU hand data to a dash, a logger or an expansion module and receive data back from sensors and controllers.
This article focuses on the bigger picture CAN data sharing and CAN network integration. Rather than concentrating on a single piece of hardware, we look at how information flows through the system, how to design that flow and how to get the benefits without overloading the bus.
From Isolated ECU to Connected System
Older engine management installations were islands. The ECU read sensors, controlled injectors and coils and perhaps sent a few analogue signals to a gauge. Adding a feature meant adding wires.
A networked approach changes the design philosophy. Devices become nodes on a shared digital bus. Each node transmits the information it owns and listens for the information it needs. This is the essence of digital communication in a modern car and it is the reason premium production vehicles and racing cars alike rely on CAN.
The advantages are concrete
Fewer wires. One twisted pair replaces many dedicated signal leads.
More data. Hundreds of channels can be shared, far beyond what analogue wiring could practically carry.
Better accuracy. Digital values do not suffer from signal drift, ground offsets or voltage noise.
Flexibility. Changing what a dash displays can be a software change, not a harness modification.
How ECU Data Communication Works on CAN
CAN is a message based protocol. Unlike a conventional network where each message is addressed to a particular recipient, a CAN node broadcasts a frame carrying an identifier and a small payload. Every node on the bus receives it and each decides whether the identifier is relevant.
Key ideas to grasp
Identifiers define meaning and priority. A lower identifier wins access to the bus when two nodes transmit simultaneously, so critical messages can be given priority.
Payloads are compact. A frame carries a handful of data bytes. Several channels are packed into one message, for example RPM and throttle together, with defined scaling and byte order.
Messages repeat at set rates. Fastchanging data, such as RPM, is sent often and slow data, such as coolant temperature, is sent less often.
Everyone shares the same medium. Total traffic must stay within what the bus can carry, a concept known as bus load.
Haltech devices use a defined communication protocol, so supported peripherals know how to interpret messages from the ECU and each other. For custom or thirdparty equipment, you set up to receive and transmit messages by hand, matching identifiers, byte positions and scaling to the device documentation.
What Can You Share Over a Haltech CAN Network?
The sharing goes in both directions.
Data the ECU can send out
Engine speed, load and throttle position
Manifold pressure and boost
Coolant, intake and oil temperatures
Ignition and fuelling information
Lambda readings and targets
Warning states and diagnostics
Data the ECU can receive
Wideband lambda values from a controller
Exhaust temperatures from a thermocouple module
Driver inputs from a CAN keypad
Additional analogue or digital inputs from an expansion module
Selected values from compatible third party devices
This two way flow is where network integration pays off. A keypad press can change a boost map, the wideband can feed fuel trim and the dash can show a warning as soon as the ECU raises it, all without extra wires.
Planning CAN Network Integration
Good integration starts with design, not wiring. Ask these questions.
What does each device need to know? A dash needs engine data. A logger may need everything. A keypad needs only to send. Define each device's role clearly.
What is the most important data? Safetycritical or tuningcritical channels deserve priority and higher update rates.
How much traffic will the bus carry? Every message you enable adds load. Aim to keep bus utilisation comfortably below the limit so there is headroom for expansion and so that no message is delayed.
How will the physical network be arranged? Follow a linear bus with proper termination and short stubs. A hub can be added where several devices cluster and the Haltech CAN hub guide covers it. For harness construction details, see the Haltech CAN bus wiring and setup guide.
How will the harness connect through the car? Bulkheads, dash panels and engine bay breakouts all need dependable connectors. A keyed motorsport connector such as the ASDD 41way flange socket is a sensible choice where a large number of circuits, including CAN, must pass through a panel in a single serviceable interface.
Configuring Data Sharing in the ECU Software
Once the network is wired, configure what is shared.
Establish the CAN port and speed. All devices must use the same data rate.
Add supported devices. Choose each peripheral so the software applies the correct message definitions.
Configure outgoing data. Decide which ECU channels are transmitted and, where it applies, their update rates.
Configure incoming data. Link each received value to an ECU channel, such as a lambda input or a switch function.
Set up custom messages for third party devices by entering identifiers, start positions, lengths, scaling and offsets from the device documentation.
Verify values against a known reference. Compare dash readings with the ECU's own channel display and confirm that units and scaling match.
Save and back up the calibration.
Be selective. It is tempting to broadcast every channel, but a network carrying unnecessary data has less capacity for what matters.
Managing Bus Load and Data Quality
A CAN bus has finite capacity. At high data rates it is generous, yet a busy network with many devices, fast update rates and long messages can approach its limits. When load is too high, lowerpriority messages are delayed or lost.
Follow these practices
Transmit only what is needed. Disable unused channels.
Match update rate to importance. Fast for RPM and boost, slower for temperatures.
Avoid duplicate sources. Two devices sending the same data waste capacity and can cause confusion.
Keep identifiers unique. Duplicate IDs cause conflicts.
Monitor. If a logger or analyser can display bus load, check it with everything running.
Data quality matters as much as quantity. Verify scaling and byte order for custom messages and test with known inputs so you can trust what you see in a race.
RealWorld Applications in Motorsport Electronics
Here is how integrated CAN communication shows up in actual projects.
Track cars. A CAN dash shows live engine data and warnings, while a keypad switches launch control, boost levels or traction settings without a pile of toggle switches.
Drag and circuit racing. Wideband and EGT modules report percylinder or perbank data to the ECU and logger, helping tuners spot lean cylinders before they cause damage.
Rally and endurance cars. A reduced harness weight, plus a wellprotected bus, improves reliability over long events. Diagnostics shared across the network help crews identify faults quickly.
Street performance builds. A tidy CAN setup lets an aftermarket ECU coexist with modern displays and accessories while keeping the cabin wiring clean.
In every case the value comes from sharing information intelligently, not from adding devices for their own sake.
Common Integration Mistakes to Avoid
Mixing data rates on the same bus
Skipping termination or adding too many terminators
Allowing long stubs that cause reflections
Broadcasting too much and creating needless bus load
Ignoring scaling on custom messages, producing misleading readings
Poor connectors and crimps that fail under vibration
No documentation, making future changes harder than necessary
Avoiding these errors keeps your network predictable.
Best Practices Summary
Design the data flow before you wire.
Build a clean linear bus with correct termination.
Use quality twisted pair cable and sealed connectors.
Share only the data you need, at appropriate rates.
Verify every channel against a trusted reference.
Document the configuration and keep backups.
Test under real running conditions, including vibration, heat and electrical load.
Conclusion
CAN data sharing turns a Haltech ECU from an isolated controller into the centre of an integrated digital network. By planning the flow of information, building a clean physical bus, configuring messages carefully and keeping bus load under control, you gain accurate data, simpler wiring and the flexibility to expand. The principles are consistent across everything from a street build to a dedicated race car design first, wire carefully, configure deliberately and test thoroughly. For connectors that keep the network dependable, visit Arctic Performance Parts.
Frequently Asked Questions (FAQs)
What is CAN data sharing?
It is the exchange of information between devices on a CAN bus. The ECU can send engine data to a dash or logger and receive data from sensors, controllers and keypads, all over the same twowire network.
Can Haltech ECUs communicate with third party devices?
Often yes, if the device uses compatible CAN settings and you configure the messages correctly. You need the device's identifiers, byte layout and scaling and you must match the data rate used on the bus.
Does sharing more data slow down the CAN network?
It increases bus load. If the bus becomes too busy, lower priority messages can be delayed or lost. Share only the channels you need and choose sensible update rates.
Do I need special software to set up Haltech CAN communication?
You configure the network in the Haltech tuning software for your ECU. Third party devices may need their own configuration tool in addition, depending on the manufacturer.
Is CAN reliable enough for motorsport use?
Yes, when installed correctly. CAN was designed for noisy automotive environments and has strong error detection. Reliability depends on good wiring, termination, connectors and sensible configuration.